ACM/IEEE SEC
2023
AdaMap: High-scalable real-time cooperative perception at the edge
Q. Liu, Y. Xue, Y. Zhang, D. Chen, and K. Han
ACM/IEEE Symposium on Edge Computing (SEC), Wilmington, DE, USA
Research question
Which data should a connected system transmit, where should it compute, and what does AI execution cost? Collaborative research develops vehicular map and perception systems, information-centric networking, offloading methods, and measurements of on-device AI. These studies make latency, information freshness, and energy trade-offs explicit.
Live high-definition map construction divides work between vehicles and edge servers under transmission, computation, and latency constraints. COMAP studies proactive provisioning of crowdsourced maps.
AdaMap combines object selection with adaptive point-cloud representation to share perception artifacts under latency constraints and changing network conditions.
DSORL selects map-data sources in vehicular named-data networking; edge-assisted indexing separates dynamic and static mixed-reality data; age-of-information-aware aggregation accounts for delayed and out-of-sequence updates.
DSORL, IEEE T-ITS 2023 · Doe et al., Intell. Converged Netw. 2024 · Mallik et al., IEEE ICC 2024
CAVE studies passing vehicles as computation resources. Related work addresses reinforcement-learning offloading for mobile augmented reality and network-aware task distribution for edge-assisted generative AI.
CAVE, IEEE GLOBECOM 2024 · REAL, IEEE TMC 2026 · Yan et al., IEEE ICC 2026
lm-Meter profiles on-device language-model latency, while related studies measure and predict deep-learning energy across edge devices and examine how prompt properties affect on-device LLM energy.
lm-Meter, ACM/IEEE SEC 2025 · Tu et al., ACM/IEEE SEC 2023 · Hu et al., EMNLP 2026
Energy predictors guide neural-architecture search in GreenAuto and PlatformX. Video-token sparsification reduces redundant visual input for driving question answering.
GreenAuto, ACM HotMobile 2025 · PlatformX, ACM/IEEE SEC 2025 · Ma et al., IEEE IV 2025
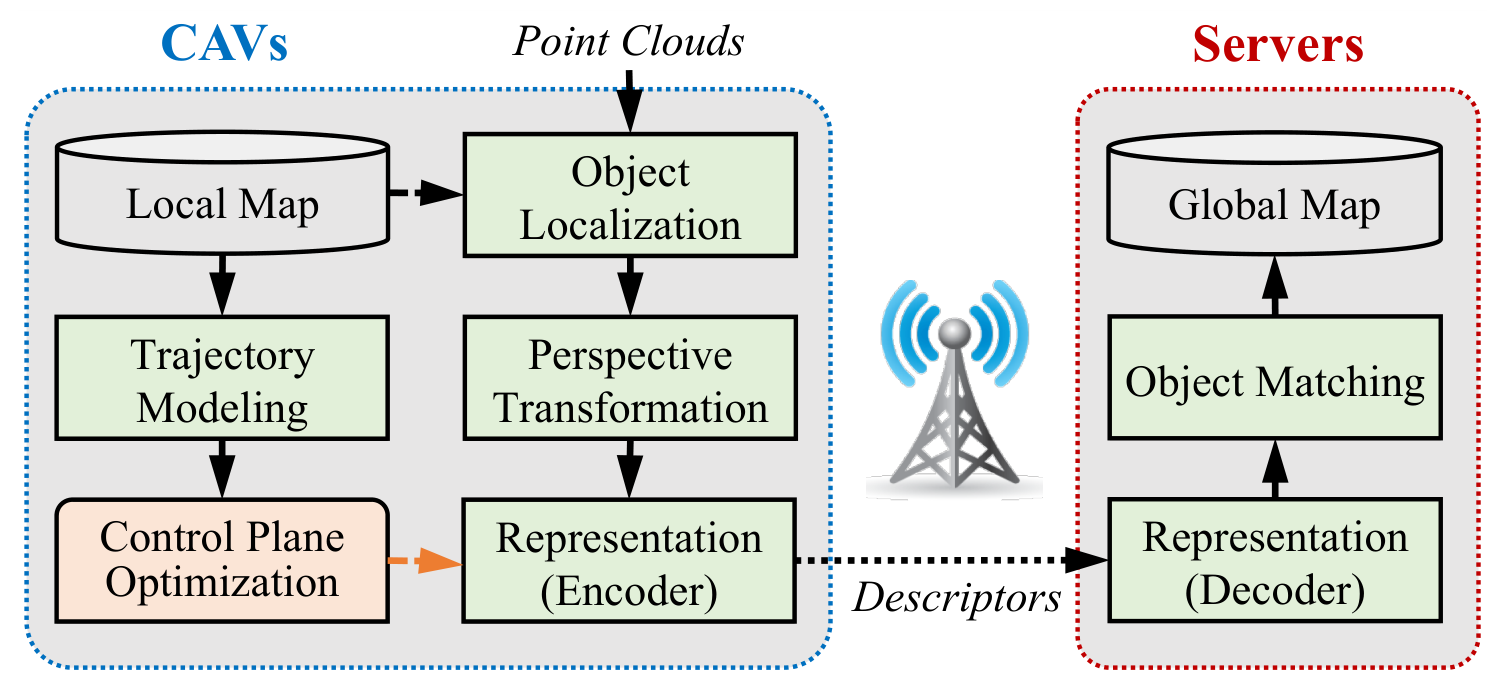
AdaMap’s published vehicle-to-edge architecture, evaluated through emulation with real computation and simulated networking.
Q. Liu et al., AdaMap: High-Scalable Real-Time Cooperative Perception at the Edge, SEC '23 (2023), Figure 3. © 2023 owner/author(s). Publication rights licensed to ACM. Rasterized/cropped from arXiv:2309.13526v2; labels unchanged. Personal use; not for redistribution. Version of Record: DOI 10.1145/3583740.3626612. Source for adamap-published-overview ACM author-reuse policy (not an open license)
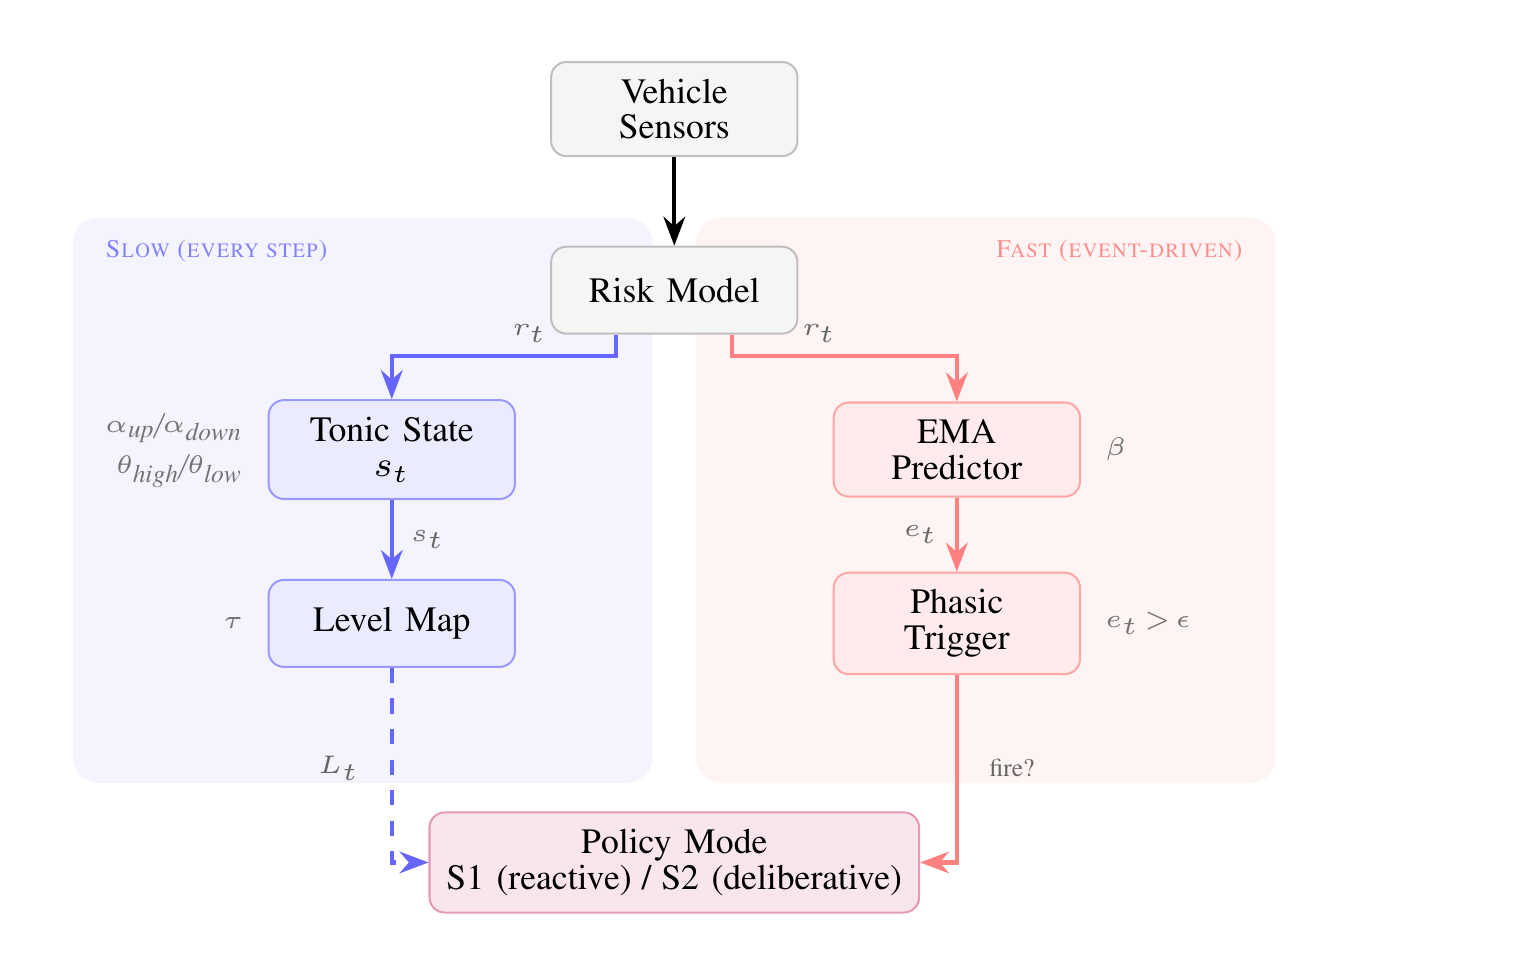
Tonic's simulation-study architecture separates persistent vigilance from surprise-triggered escalation.
Kyungtae Han and coauthors (2026), existing public Tonic Meta-Control project, architecture figure; unchanged. Source for tonic-architecture
A curated selection. Citations above link to each paper; see the full publication list for all work.
Q. Liu, Y. Xue, Y. Zhang, D. Chen, and K. Han
ACM/IEEE Symposium on Edge Computing (SEC), Wilmington, DE, USA
H. Wang, X. Tu, H. Ke, H. Chai, D. Chen, and K. Han
10th Symposium on Edge Computing (SEC 2025)
Y. Zhang, Q. Liu, H. Wang, D. Chen, and K. Han
IEEE Transactions on Vehicular Technology, vol. 73, no. 9, pp. 13569–13583
D. Doe, D. Chen, K. Han, H. Wang, J. Xie, and Z. Han
IEEE Transactions on Intelligent Transportation Systems, vol. 24, no. 10, pp. 11225–11237
A. Mallik, D. Chen, K. Han, L. Jiang, and Z. Han
IEEE International Conference on Communications (ICC): Mobile and Wireless Networks Symposium, Denver, CO, USA
X. Tu, A. Mallik, D. Chen, K. Han, O. Altintas, H. Wang, and J. Xie
ACM/IEEE Symposium on Edge Computing (SEC), Wilmington, DE, USA