Digital Twins and Cooperative Mobility

Research question

How can shared digital representations help vehicles coordinate? Collaborative research connects vehicle, driver, and traffic models with vehicle-to-cloud communication, develops cooperative maneuver methods, and builds platforms for studying mixed traffic. Evaluations range from Unity–SUMO co-simulation to controlled passenger-vehicle field studies of ramp-merging advisories.

Methods & contributions

  1. Cooperative ramp merging with connected digital twins

    Vehicle and driver digital twins support ramp-merging advisories over cellular vehicle-to-cloud links. A related game-theoretic method studies mixed automated and human-driven traffic with Unity–SUMO co-simulation.

    Liao et al., IEEE T-ITS 2022 · Liao et al., IEEE T-SMC 2022 · Wang et al., SAE JCAV 2019

  2. Cooperative intersections and roundabouts

    Digital-twin-assisted methods extend cooperative-driving studies to non-signalized intersections and roundabouts. These investigate different maneuver geometries through simulation and co-simulation.

    Wang et al., IEEE T-IV 2022 · Li et al., IEEE FISTS 2024

  3. Architecture and experimental platforms

    Mobility Digital Twin organizes human, vehicle, and traffic twins on a cloud–edge–device architecture. Unity and Unity–SUMO platforms support simulation and co-simulation of connected vehicles and mixed traffic.

    Wang et al., IEEE IoT-J 2022 · Wang et al., IEEE DTPI 2021 · Zhao et al., SAE JCAV 2022

  4. Identifying senders and estimating motion over imperfect links

    V2V sender identification associates messages with surrounding vehicles, while motion estimation accounts for communication delay and packet loss.

    Kobayashi et al., IEEE VTC 2019 · Wang et al., SAE WCX 2021

  5. Cooperative control and exchanged intent

    Lookup-table consensus studies longitudinal coordination, while a separate prototype-vehicle study examines platooning with communicated intent. Edge-assisted misbehavior detection investigates another vulnerability of platoon coordination.

    Wang et al., ACC 2019 · Sharma et al., IEEE INFOCOM 2026 (poster) · Kan et al., IEEE VNC 2019

  6. Making connected information available to drivers

    Augmented-reality assistance explores how connected-vehicle information can be presented to a driver.

    Wang et al., IEEE SMC 2020

Visual overview

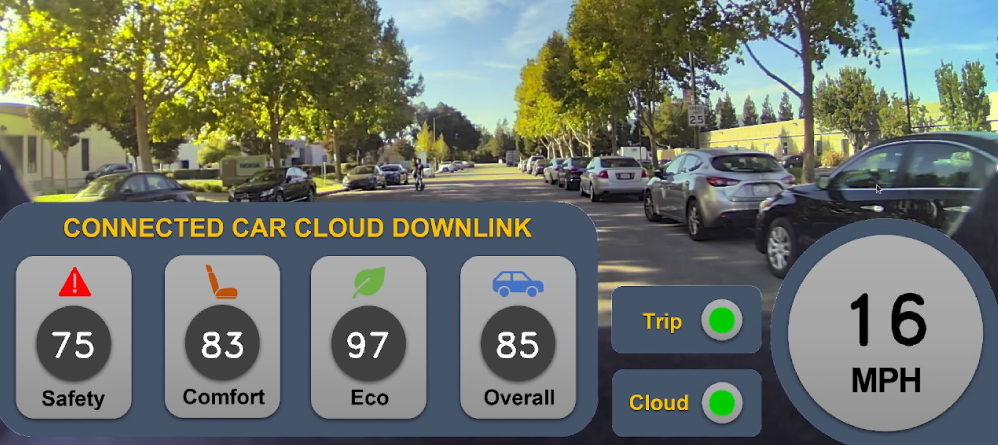
Mobility Digital Twin's cloud-based driver-scoring demonstration in Mountain View, California.

Z. Wang et al., Mobility Digital Twin: Concept, Architecture, Case Study, and Future Challenges, IEEE IoT Journal (2022), Figure 3. DOI: 10.1109/JIOT.2022.3156028. © 2022 IEEE. Extracted from author manuscript; labels unchanged. Reused for the coauthor's personal academic use; no IEEE endorsement. Source for mobility-driver-scoring-field IEEE author-retained rights (not an open license)

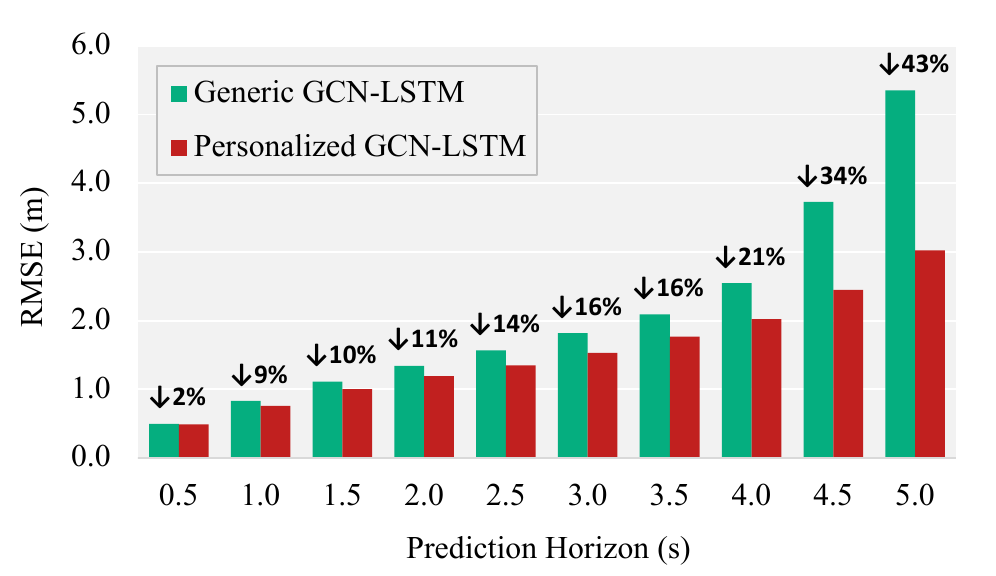
Generic and personalized GCN-LSTM trajectory prediction compared on human-in-the-loop simulation data.

Amr Abdelraouf, Rohit Gupta, and Kyungtae Han (2023), Figure 4, arXiv:2308.07439v2. CC BY 4.0. Rasterized and cropped from the author preprint; data and labels unchanged. Source for personalized-trajectory-results CC BY 4.0

Systems & evidence

Representative publications

A curated selection. Citations above link to each paper; see the full publication list for all work.

IEEE T-ITS 2022

Cooperative Ramp Merging Design and Field Implementation: A Digital Twin Approach Based on Vehicle-to-Cloud Communication

X. Liao, Z. Wang, X. Zhao, K. Han, P. Tiwari, M. Barth, and G. Wu

IEEE Transactions on Intelligent Transportation Systems, vol. 23, no. 5, pp. 4490–4500

IEEE IoT-J 2022

Mobility Digital Twin: Concept, Architecture, Case Study, and Future Challenges

Z. Wang, R. Gupta, K. Han, H. Wang, A. Ganlath, N. Ammar, and P. Tiwari

IEEE Internet of Things Journal, vol. 9, no. 18, pp. 17452–17467

IEEE T-SMC 2022

Game Theory-Based Ramp Merging for Mixed Traffic With Unity-SUMO Co-Simulation

X. Liao, X. Zhao, Z. Wang, K. Han, P. Tiwari, M. Barth, and G. Wu

IEEE Transactions on Systems, Man, and Cybernetics: Systems, vol. 52, no. 9, pp. 5746–5757

IEEE T-IV 2022

Digital Twin-Assisted Cooperative Driving at Non-Signalized Intersections

Z. Wang, K. Han, and P. Tiwari

IEEE Transactions on Intelligent Vehicles, vol. 7, no. 2, pp. 198--209

SAE JCAV 2022

Co-Simulation Platform for Modeling and Evaluating Connected and Automated Vehicles in Mixed Traffic

X. Zhao, X. Liao, G. Wu, M. Barth, Z. Wang, K. Han, and P. Tiwari

SAE International Journal of Connected and Automated Vehicles, vol. 5, no. 4, pp. 313--326

IEEE INFOCOM 2026Poster

Using Intent Communication to Enhance Platooning: Validation with Prototype Vehicles

S. Sharma, A. Moradipari, S. Avedisov, M. Nour, S. Mishra, K. Han, A. Abdelraouf, T. Shimizu, and O. Altintas

IEEE INFOCOM 2026, Tokyo, Japan

Full publication list